
Hi! My friend and I have a CAD project where we're designing a steering system for a go-kart. We want to achieve Ackermann steering and have decided to use a pitman arm with two attachment points to each steering arm on the steering knuckle. All measurements should align when the wheels are pointing straight ahead, but when we start turning, the distance between the holes on the steering rods changes because the Ackermann holes end up overlapping. Do you have any tips on how we should proceed?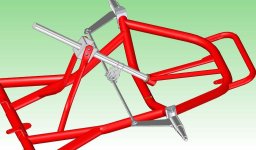


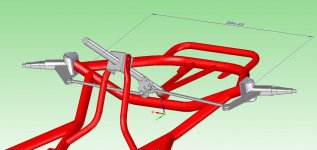

 I do not have enough info, where is the animation?


